Pick and place
Picking parts, placing them on the mark, and moving them between processes
 Asher Kim Portfolio №02 · This is a fictional company. No real quotes, orders, or consultations. · Fictional company
HG-DWG-000 · Hangyeol Robotics website
SCARA HG-S
4-axis SCARA for fast transfer and assembly, 500–700 mm arms
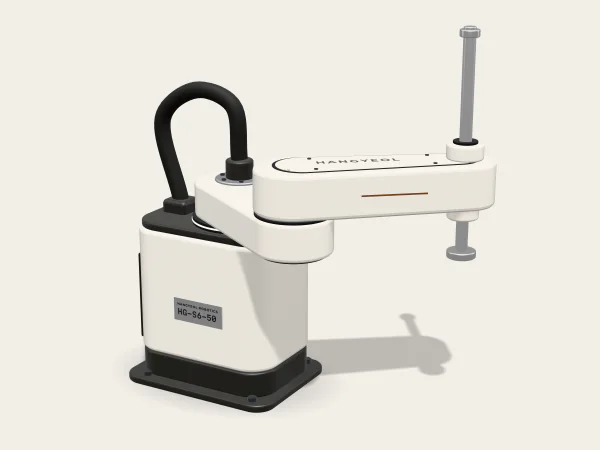
Four-axis robots that move fast across the plane and place precisely on the way down. The HG-S6-50 runs the standard cycle in 0.32 s. Mount them on a table, wall, or ceiling, with cleanroom and IP65 versions available.
Models
Numbers line up in fixed-width columns. Add any model to compare it with robots from other families.
| Model | Payload (rated) | Arm length | XY repeatability | Standard cycle time | Z stroke | Weight | Compare |
|---|---|---|---|---|---|---|---|
| HG-S6-50 | 3kg6.6 lbmax 6 kg | 500mm19.7 in | ±0.01mm | 0.32s | 200mm7.9 in | 30kg66 lb | |
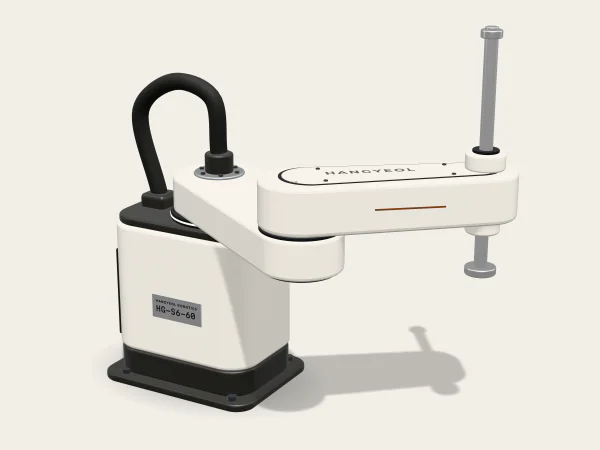
| HG-S6-60 | 3kg6.6 lbmax 6 kg | 600mm23.6 in | ±0.01mm | 0.34s | 200mm7.9 in | 31kg68 lb | |
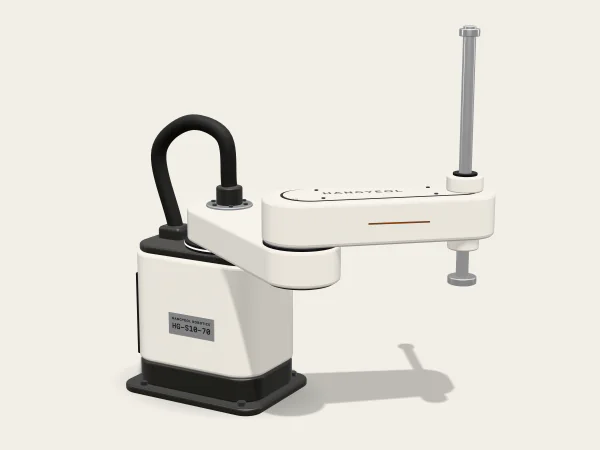
| HG-S10-70 | 5kg11 lbmax 10 kg | 700mm27.6 in | ±0.015mm | 0.38s | 300mm11.8 in | 37kg82 lb |
Same scale
Every model is drawn at the same scale on one floor line. The bars below give reach at the same scale.
What all three share
The HG-S6-50 runs the standard cycle (2 kg, 300 mm across, 25 mm up and down) in 0.32 s. Every model is measured the same way, so you can compare them directly.
Both HG-S6 models repeat to ±0.01 mm in XY and in Z. That is tight enough to press small connectors into board holes.
One robot, three mounting options. Ceiling mounting frees up the whole table below.
Choose the cleanroom version for PCB and display lines, or the IP65 version where water and dust are present.
Applications
Each application page shows the motion path, the process steps, and the models we recommend.
Picking parts, placing them on the mark, and moving them between processes
Driving bolts and screws to torque and fitting parts together
Carrying cameras and sensors to every check point in the same order
Laying sealant and adhesive in one even, unbroken bead
Tell us what the robot has to lift, how far it has to reach, and how fast the line runs. An engineer will reply with a model and a cell layout.