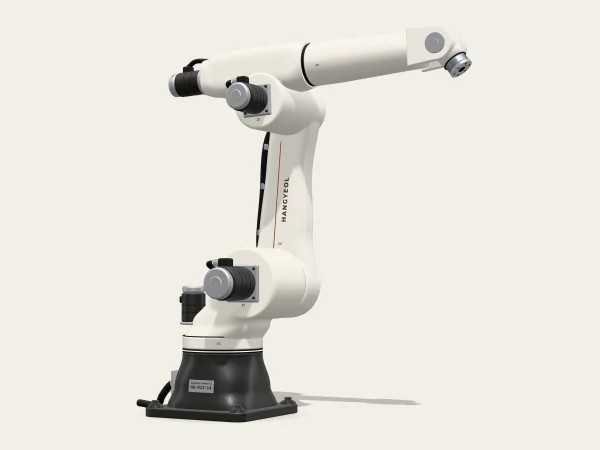
Industrial 6-axis
HG-R12-14
A 12 kg, 1,400 mm mid-size arm for arc welding and small-part handling
- Payload
- 12kg
- 26 lb
- Reach
- 1,400mm
- 55.1 in
- Repeatability
- ±0.02mm
 Asher Kim Portfolio №02 · This is a fictional company. No real quotes, orders, or consultations. · Fictional company
HG-DWG-000 · Hangyeol Robotics website
Application 8 of 8
The nozzle follows the contour at constant speed and lays one continuous bead. Speed and flow have to match for an even bead.
Process sequence
Scroll down and each step lights up in copper on the plate.
The part is clamped in the fixture.
A camera reads the part position and shifts the path.
The nozzle follows the contour at constant speed.
A camera checks bead width and gaps.
The nozzle tip is wiped so the next bead starts clean.
Design points
When the robot slows for a corner, the flow must drop too. The HGC-7 sends a speed-matched signal to the dispenser.
Decide in advance where the bead overlaps, and start the flow a moment early to avoid a gap.
Viscosity changes with temperature, and the bead changes with it. Keep the material at a steady temperature.
Recommended robots
A bead that breaks or changes width will leak or let go. The robot holds speed through corners and talks to the dispenser, so the flow follows the speed.
Use the HG-R12-14 for large parts such as body-panel sealing, and the HG-C5-09 cobot or the HG-S6-50 SCARA for adhesive on small electronics.
For high-volume jobs like thermal paste on battery modules, mount a large nozzle on the HG-R25-18.
Industrial 6-axis
A 12 kg, 1,400 mm mid-size arm for arc welding and small-part handling
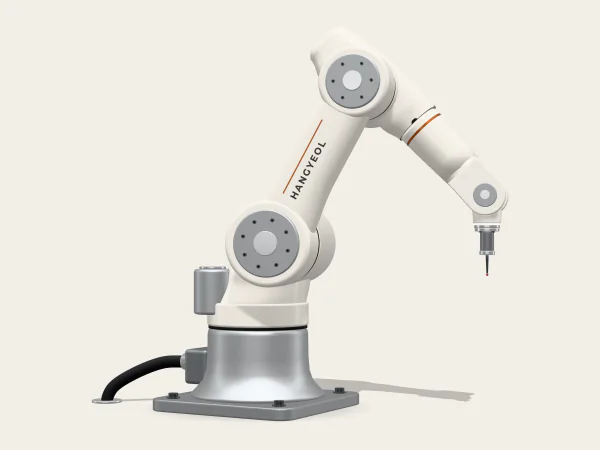
Collaborative robots
Our flagship cobot: 10 kg and 1,300 mm, from machine tending to welding
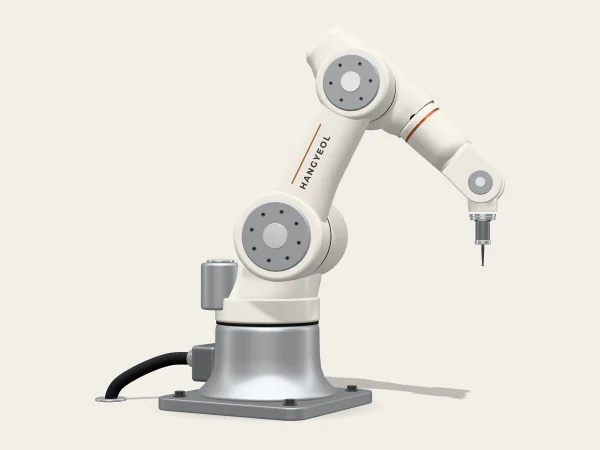
Collaborative robots
Our smallest cobot: 5 kg and 900 mm, sized for benchtop assembly, inspection, and dispensing
Other models that fit
Cases
We have not published a case for this process yet. Here are plants in the same industries that run Hangyeol robots.
Gyeongsan, Gyeongbuk · Automotive seat-parts maker
HG-R12-14 × 4
19%Shorter cycle timeExample
Ochang, Chungbuk · Battery module maker
HG-C16-10 × 6
0boltsMissed fastenings, first 3 monthsExample
Cheonan, Chungnam · Electronic components maker
HG-S6-50 × 8
0.41 → 0.33sCycle time per partExample
Industries that use this process most
Share part drawings or a video of the current process. An application engineer will work through the cell layout and cycle time with you.