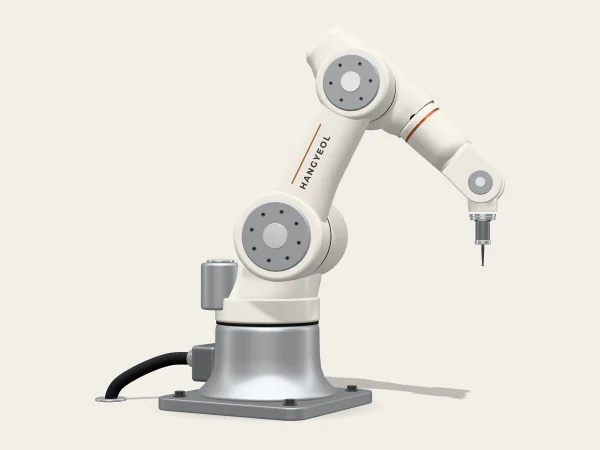
Collaborative robots
HG-C5-09
Our smallest cobot: 5 kg and 900 mm, sized for benchtop assembly, inspection, and dispensing
- Payload
- 5kg
- 11 lb
- Reach
- 900mm
- 35.4 in
- Repeatability
- ±0.03mm
 Asher Kim Portfolio №02 · This is a fictional company. No real quotes, orders, or consultations. · Fictional company
HG-DWG-000 · Hangyeol Robotics website
Application 7 of 8
With a camera at the wrist, the robot stops at each check point in turn. Same angle, same distance, every time, so the judgment stays consistent.
Process sequence
Scroll down and each step lights up in copper on the plate.
The part arrives and stops at the inspection station.
The robot stops at each set pose and takes an image.
Each image is compared against the criteria for pass or fail.
Results are stored with the serial number, and rejects are set aside.
Design points
Mount the light next to the camera, and changes in ceiling lights or daylight no longer shift the image.
Shooting on the move is faster but blurrier. Stop for precision checks, and shoot on the fly only for presence checks.
Agree on good and bad reference samples together, then tune the judgment against them during commissioning.
Recommended robots
Manual visual inspection drifts with fatigue and lighting. A robot brings the camera to the programmed pose every time, so images stay consistent and pass/fail criteria can be set in numbers.
For small parts, an HG-C5-09 cobot or an HG-S6-50 SCARA carries the camera. In a fastening cell, the robot that drove the bolts checks them too.
The HGC-7 sends the results to the line PLC, and rejects never reach the next process.
Collaborative robots
Our smallest cobot: 5 kg and 900 mm, sized for benchtop assembly, inspection, and dispensing
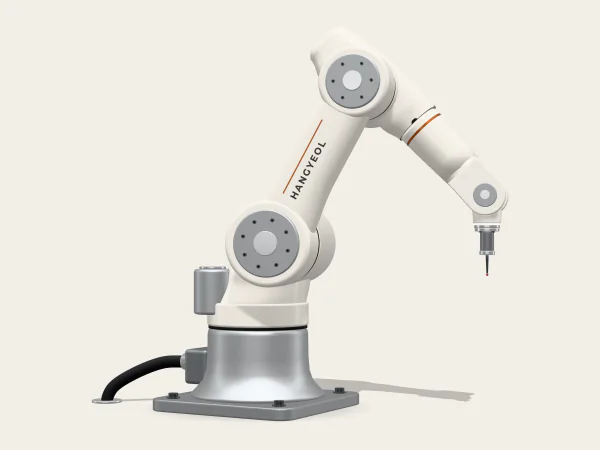
Collaborative robots
Our flagship cobot: 10 kg and 1,300 mm, from machine tending to welding
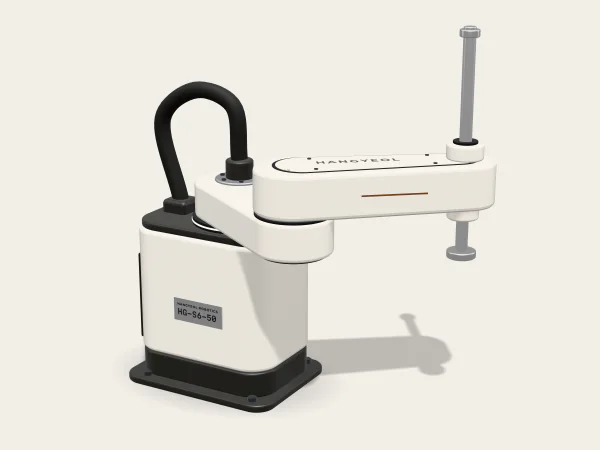
SCARA
A 500 mm SCARA with a 0.32 s standard cycle for fast small-part work on boards
Other models that fit
Cases
Ochang, Chungbuk · Battery module maker
HG-C16-10 × 6
0boltsMissed fastenings, first 3 monthsExample
Industries that use this process most
Share part drawings or a video of the current process. An application engineer will work through the cell layout and cycle time with you.