
Compare
Side by side, the differences show.
Put two to four models next to each other. Matching specs share a row, and rows with different values are marked.
- Title
- Overlaid front views
- Drawing no.
- HG-DWG-160
- Scale
- Same
- Unit
- mm
Pick models to compare
Choose two to four. Your picks also go into the compare tray, so they follow you around the product pages.
HG-CCollaborative robots
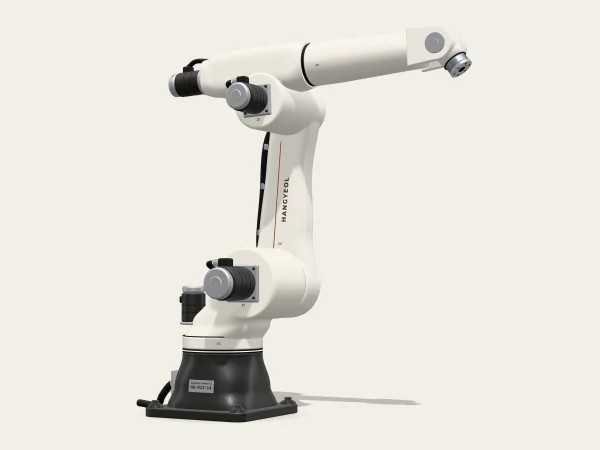
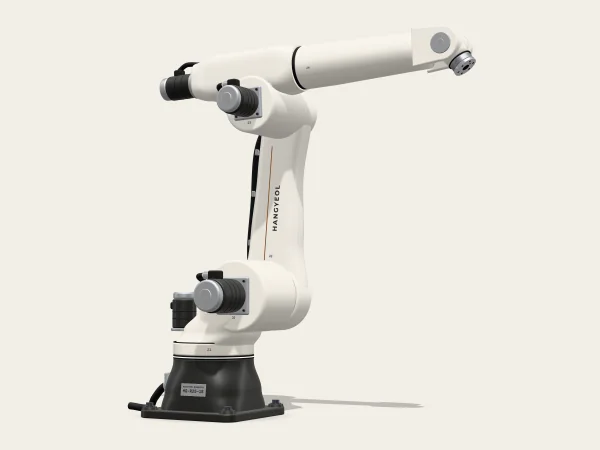
HG-RIndustrial 6-axis robots
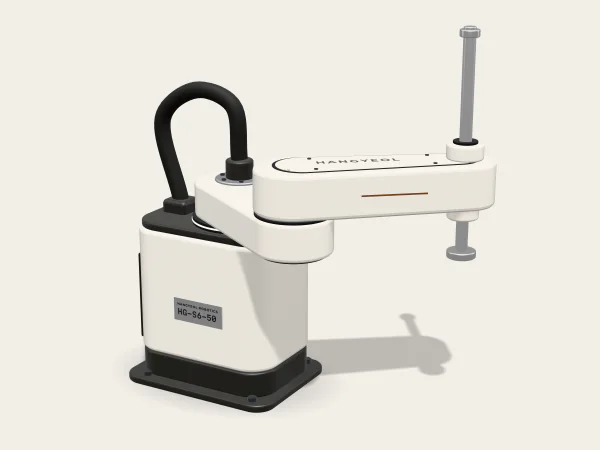
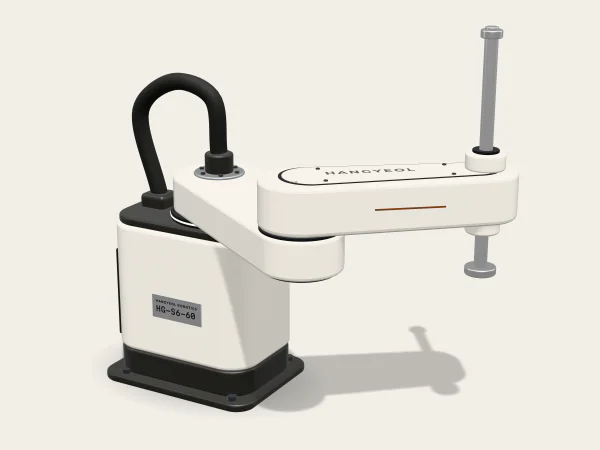
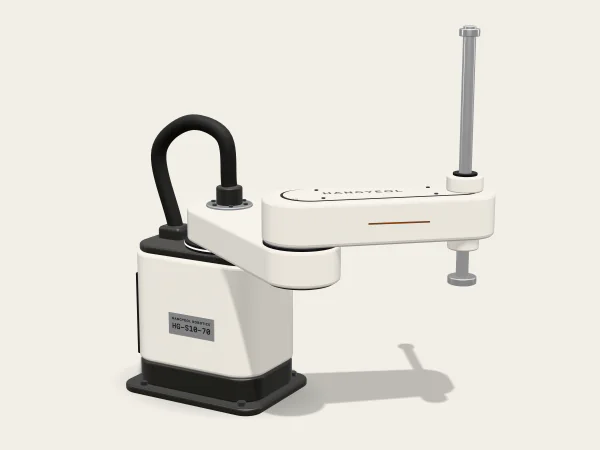
HG-SSCARA robots
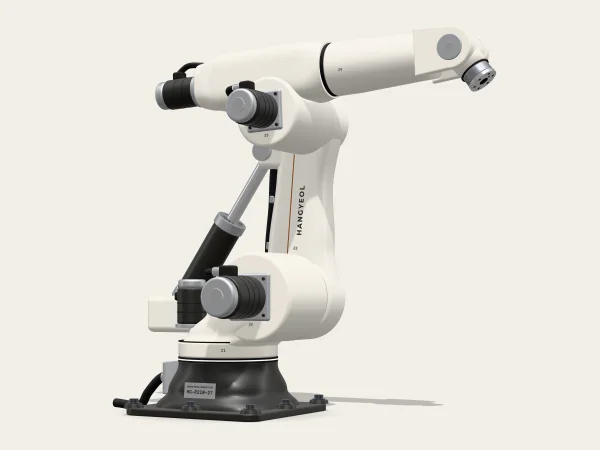
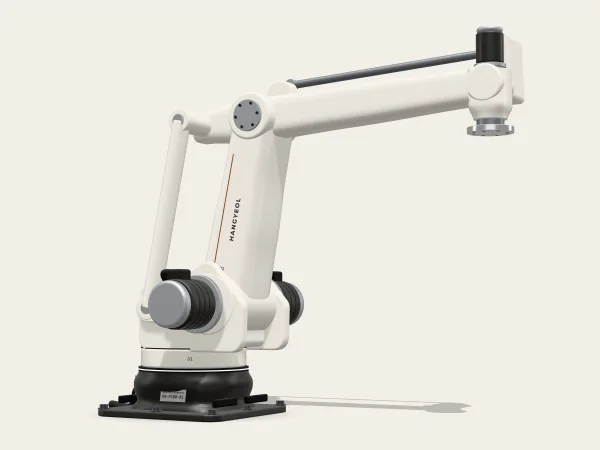
HG-PPalletizing robots
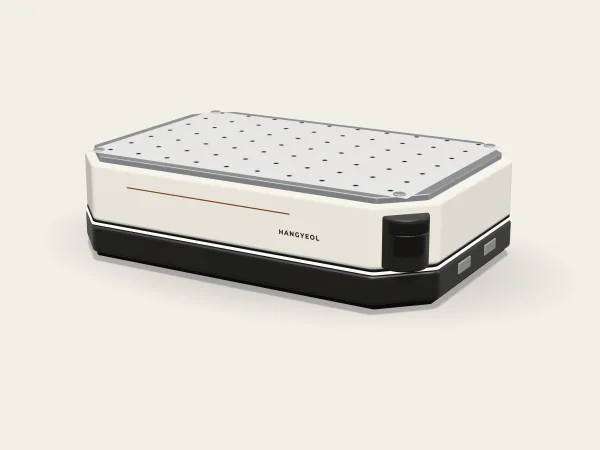
HG-MMobile robots
Compare robots
| Model | ||||||||||||||
| At a glance | ||||||||||||||
| Payload(Differs) | 5kg | 10kg | 16kg | 25kg | 12kg | 25kg | 210kg | 3kg | 3kg | 5kg | 180kg | — | 10kg | |
| Reach(Differs) | 900mm | 1,300mm | 1,000mm | 1,700mm | 1,400mm | 1,800mm | 2,700mm | 500mm | 600mm | 700mm | 3,100mm | — | 1,300mm | |
| Weight(Differs) | 22kg | 33kg | 34kg | 72kg | 158kg | 236kg | 1,120kg | 30kg | 31kg | 37kg | 1,300kg | 165kg | 231kg | |
| Basics | ||||||||||||||
| Payload(Differs) | 5kg11 lb | 10kg22 lb | 16kg35 lb | 25kg55 lb | 12kg26 lb | 25kg55 lb | 210kg463 lb | 3kg6.6 lbPayload (rated)max 6 kg | 3kg6.6 lbPayload (rated)max 6 kg | 5kg11 lbPayload (rated)max 10 kg | 180kg397 lb | — | 10kg22 lbArm payload | |
| Reach(Differs) | 900mm35.4 in | 1,300mm51.2 in | 1,000mm39.4 in | 1,700mm66.9 in | 1,400mm55.1 in | 1,800mm70.9 in | 2,700mm106.3 in | 500mm19.7 inArm lengthArm 1 225 mm + arm 2 275 mm | 600mm23.6 inArm lengthArm 1 325 mm + arm 2 275 mm | 700mm27.6 inArm lengthArm 1 375 mm + arm 2 325 mm | 3,100mm122 in | — | 1,300mm51.2 inArm reach | |
| Repeatability(Differs) | ±0.03mmPer ISO 9283 | ±0.03mmPer ISO 9283 | ±0.05mmPer ISO 9283 | ±0.1mmPer ISO 9283 | ±0.02mmPer ISO 9283 | ±0.02mmPer ISO 9283 | ±0.05mmPer ISO 9283 | ±0.01mmXY repeatabilityPer ISO 9283 | ±0.01mmXY repeatabilityPer ISO 9283 | ±0.015mmXY repeatabilityPer ISO 9283 | ±0.05mmPer ISO 9283 | — | — | |
| Axes(Differs) | 6 | 6 | 6 | 6 | 6 | 6 | 6 | 4 | 4 | 4 | 4 | — | — | |
| Weight(Differs) | 22kg49 lbWithout cable | 33kg73 lbWithout cable | 34kg75 lbWithout cable | 72kg159 lbWithout cable | 158kg348 lb | 236kg520 lb | 1,120kg2,469 lb | 30kg66 lb | 31kg68 lb | 37kg82 lb | 1,300kg2,866 lb | 165kg364 lb | 231kg509 lbArm included | |
| Mounting(Differs) | Any orientation: floor, wall, ceiling, or tilted | Any orientation: floor, wall, ceiling, or tilted | Any orientation: floor, wall, ceiling, or tilted | Any orientation: floor, wall, ceiling, or tilted | Floor, ceiling, or wall | Floor, ceiling, or wall | Floor | Table, wall, or ceiling | Table, wall, or ceiling | Table, wall, or ceiling | Floor | — | — | |
| Base diameter(Differs) | 150mm5.9 in | 190mm7.5 in | 190mm7.5 in | 245mm9.6 in | 400 × 400mmBase size | 460 × 460mmBase size | 980 × 980mmBase size | 190 × 270mmBase size | 190 × 270mmBase size | 220 × 320mmBase size | 1,000 × 1,000mmBase size | — | — | |
| Tool flange(Differs) | ISO 9409-1-50-4-M6 | ISO 9409-1-50-4-M6 | ISO 9409-1-63-4-M6 | ISO 9409-1-80-6-M8 | — | — | — | — | — | — | — | — | — | |
| Payload (max)(Differs) | — | — | — | — | — | — | — | 6kg13 lb | 6kg13 lb | 10kg22 lb | — | — | — | |
| Z repeatability(Differs) | — | — | — | — | — | — | — | ±0.01mm | ±0.01mm | ±0.01mm | — | — | — | |
| R repeatability(Differs) | — | — | — | — | — | — | — | ±0.005° | ±0.005° | ±0.005° | — | — | — | |
| Load(Differs) | — | — | — | — | — | — | — | — | — | — | — | 600kg1,323 lb | 100kg220 lbParts shelf load | |
| Length(Differs) | — | — | — | — | — | — | — | — | — | — | — | 1,120mm44.1 in | 1,120mm44.1 in | |
| Width(Differs) | — | — | — | — | — | — | — | — | — | — | — | 760mm29.9 in | 760mm29.9 in | |
| Height(Differs) | — | — | — | — | — | — | — | — | — | — | — | 300mm11.8 in | — | |
| Deck(Differs) | — | — | — | — | — | — | — | — | — | — | — | Aluminum with an M8 tapped grid for lift or conveyor modules | — | |
| Arm(Differs) | — | — | — | — | — | — | — | — | — | — | — | — | HG-C10-13 | |
| Arm repeatability(Differs) | — | — | — | — | — | — | — | — | — | — | — | — | ±0.03mmPer ISO 9283 | |
| Work position accuracy(Differs) | — | — | — | — | — | — | — | — | — | — | — | — | ±0.2mmAfter correction with the wrist camera on a station marker | |
| Arm base height(Differs) | — | — | — | — | — | — | — | — | — | — | — | — | 630mm24.8 inFrom the floor | |
| Wrist load capacity | ||||||||||||||
| J4 allowable moment(Differs) | — | — | — | — | 26N·m | 55N·m | 1,250N·m | — | — | — | — | — | — | |
| J5 allowable moment(Differs) | — | — | — | — | 26N·m | 55N·m | 1,250N·m | — | — | — | — | — | — | |
| J6 allowable moment(Differs) | — | — | — | — | 11N·m | 30N·m | 650N·m | — | — | — | — | — | — | |
| J4 allowable inertia(Differs) | — | — | — | — | 0.9kg·m² | 2.2kg·m² | 120kg·m² | — | — | — | — | — | — | |
| J5 allowable inertia(Differs) | — | — | — | — | 0.9kg·m² | 2.2kg·m² | 120kg·m² | — | — | — | — | — | — | |
| J6 allowable inertia(Differs) | — | — | — | — | 0.3kg·m² | 0.9kg·m² | 60kg·m² | — | — | — | — | — | — | |
| Motion · Driving | ||||||||||||||
| Max TCP speed(Differs) | 1m/s | 2m/s | 1.5m/s | 2m/s | — | — | — | — | — | — | — | — | 2m/sArm max TCP speed | |
| Force sensing(Differs) | Torque sensors in all six joints (2nd gen) | Torque sensors in all six joints (2nd gen) | Torque sensors in all six joints (2nd gen) | Torque sensors in all six joints (2nd gen) | — | — | — | — | — | — | — | — | — | |
| TCP force accuracy(Differs) | ±3N | ±4N | ±5N | ±8N | — | — | — | — | — | — | — | — | — | |
| Hand guiding(Differs) | Press the wrist button, guide the arm, save the point | Press the wrist button, guide the arm, save the point | Press the wrist button, guide the arm, save the point | Press the wrist button, guide the arm, save the point | — | — | — | — | — | — | — | — | — | |
| Standard cycle time(Differs) | — | — | — | — | — | — | — | 0.32s2 kg, 300 mm horizontal and 25 mm vertical, round trip | 0.34s2 kg, 300 mm horizontal and 25 mm vertical, round trip | 0.38s2 kg, 300 mm horizontal and 25 mm vertical, round trip | — | — | — | |
| Max XY speed(Differs) | — | — | — | — | — | — | — | 8,400mm/s | 8,700mm/s | 9,000mm/s | — | — | — | |
| Z stroke(Differs) | — | — | — | — | — | — | — | 200mm7.9 in300 mm option | 200mm7.9 in300 mm option | 300mm11.8 in200 mm option | — | — | — | |
| Push-down force(Differs) | — | — | — | — | — | — | — | 150N | 150N | 200N | — | — | — | |
| J4 allowable inertia (rated / max)(Differs) | — | — | — | — | — | — | — | 0.01 / 0.12kg·m² | 0.01 / 0.12kg·m² | 0.02 / 0.25kg·m² | 100kg·m²J4 allowable inertia | — | — | |
| Cycles per hour(Differs) | — | — | — | — | — | — | — | — | — | — | 1,800/hAt 180 kg on the 400–2,000–400 mm pattern | — | — | |
| Cycles per hour at 120 kg(Differs) | — | — | — | — | — | — | — | — | — | — | 2,000/h400–2,000–400 mm pattern | — | — | |
| Wrist attitude(Differs) | — | — | — | — | — | — | — | — | — | — | Held level by parallel links | — | — | |
| Top speed(Differs) | — | — | — | — | — | — | — | — | — | — | — | 1.5m/sEmpty | 1.5m/sWith the arm folded and locked | |
| Speed at full load(Differs) | — | — | — | — | — | — | — | — | — | — | — | 1.2m/s | — | |
| Turning(Differs) | — | — | — | — | — | — | — | — | — | — | — | Turns in place (zero radius) | Turns in place (zero radius) | |
| Turning space(Differs) | — | — | — | — | — | — | — | — | — | — | — | 1,400mm55.1 inDiameter | 1,400mm55.1 inDiameter | |
| Minimum aisle width(Differs) | — | — | — | — | — | — | — | — | — | — | — | 1,000mm39.4 inOne-way traffic | 1,000mm39.4 inOne-way traffic | |
| Docking accuracy(Differs) | — | — | — | — | — | — | — | — | — | — | — | ±3mm | ±3mm | |
| Positioning accuracy in transit(Differs) | — | — | — | — | — | — | — | — | — | — | — | ±100mm | ±100mm | |
| Navigation(Differs) | — | — | — | — | — | — | — | — | — | — | — | Laser-map navigation; reflective markers for docking | Laser-map navigation; reflective markers for docking | |
| Max step and gap(Differs) | — | — | — | — | — | — | — | — | — | — | — | 10 / 20mm | 10 / 20mm | |
| Joint range and speed | ||||||||||||||
| J1 base swivel range(Differs) | ±360° | ±360° | ±360° | ±360° | ±170° | ±170° | ±180° | ±132°J1 arm 1 range | ±132°J1 arm 1 range | ±132°J1 arm 1 range | ±180° | — | ±360° | |
| J1 max speed(Differs) | 120°/s | 120°/s | 120°/s | 120°/s | 200°/s | 200°/s | 100°/s | 450°/s | 430°/s | 400°/s | 130°/s | — | 120°/s | |
| J2 shoulder range(Differs) | ±360° | ±360° | ±360° | ±360° | −90° to +150°J2 lower arm range | −90° to +150°J2 lower arm range | −60° to +85°J2 lower arm range | ±150°J2 arm 2 range | ±150°J2 arm 2 range | ±150°J2 arm 2 range | −40° to +65°J2 lower arm range | — | ±360° | |
| J2 max speed(Differs) | 120°/s | 120°/s | 120°/s | 120°/s | 190°/s | 180°/s | 95°/s | 960°/s | 900°/s | 760°/s | 125°/s | — | 120°/s | |
| J3 elbow range(Differs) | ±165° | ±165° | ±165° | ±165° | −185° to +75°J3 upper arm range | −185° to +75°J3 upper arm range | −150° to +70°J3 upper arm range | 200mm7.9 inJ3 vertical (Z) stroke | 200mm7.9 inJ3 vertical (Z) stroke | 300mm11.8 inJ3 vertical (Z) stroke | −60° to +25°J3 forearm range | — | ±165° | |
| J3 max speed(Differs) | 180°/s | 180°/s | 180°/s | 150°/s | 210°/s | 200°/s | 95°/s | 2,000mm/s | 2,000mm/s | 1,800mm/s | 125°/s | — | 180°/s | |
| J4 wrist 1 range(Differs) | ±360° | ±360° | ±360° | ±360° | ±200°J4 arm roll range | ±200°J4 arm roll range | ±360°J4 arm roll range | ±360°J4 rotation (R) range | ±360°J4 rotation (R) range | ±360°J4 rotation (R) range | ±360°J4 wrist roll range | — | ±360° | |
| J4 max speed(Differs) | 180°/s | 180°/s | 180°/s | 180°/s | 400°/s | 370°/s | 120°/s | 2,500°/s | 2,500°/s | 2,000°/s | 330°/s | — | 180°/s | |
| J5 wrist 2 range(Differs) | ±360° | ±360° | ±360° | ±360° | ±135°J5 wrist bend range | ±135°J5 wrist bend range | ±125°J5 wrist bend range | — | — | — | — | — | ±360° | |
| J5 max speed(Differs) | 180°/s | 180°/s | 180°/s | 180°/s | 400°/s | 370°/s | 120°/s | — | — | — | — | — | 180°/s | |
| J6 wrist 3 range(Differs) | ±360° | ±360° | ±360° | ±360° | ±450°J6 wrist roll range | ±450°J6 wrist roll range | ±360°J6 wrist roll range | — | — | — | — | — | ±360° | |
| J6 max speed(Differs) | 180°/s | 180°/s | 180°/s | 180°/s | 720°/s | 720°/s | 190°/s | — | — | — | — | — | 180°/s | |
| Battery and charging | ||||||||||||||
| Battery(Differs) | — | — | — | — | — | — | — | — | — | — | — | Lithium iron phosphate, 48 V, 70 Ah | Lithium iron phosphate, 48 V, 70 Ah | |
| Run time(Differs) | — | — | — | — | — | — | — | — | — | — | — | 8hAt full load; 11 h empty | 6hIncluding arm work | |
| Charge time(Differs) | — | — | — | — | — | — | — | — | — | — | — | 3h0 to 100% | 3h0 to 100% | |
| Charging(Differs) | — | — | — | — | — | — | — | — | — | — | — | Automatic dock or manual charger | Automatic dock or manual charger | |
| Battery life(Differs) | — | — | — | — | — | — | — | — | — | — | — | 3,000+ cycles | 3,000+ cycles | |
| Power and communication | ||||||||||||||
| Controller(Differs) | HGC-7 compact cabinet | HGC-7 compact cabinet | HGC-7 compact cabinet | HGC-7 compact cabinet | HGC-7 standard cabinet | HGC-7 standard cabinet | HGC-7 standard cabinet | HGC-7 compact cabinet | HGC-7 compact cabinet | HGC-7 compact cabinet | HGC-7 standard cabinet | HGC-7, built in (48 V DC) | HGC-7, built in: one controller for base and arm | |
| Power supply(Differs) | Single-phase 100–240 VAC, 50/60 Hz | Single-phase 100–240 VAC, 50/60 Hz | Single-phase 100–240 VAC, 50/60 Hz | Single-phase 100–240 VAC, 50/60 Hz | 3-phase 380–480 VAC, 50/60 Hz | 3-phase 380–480 VAC, 50/60 Hz | 3-phase 380–480 VAC, 50/60 Hz | Single-phase 200–240 VAC, 50/60 Hz | Single-phase 200–240 VAC, 50/60 Hz | Single-phase 200–240 VAC, 50/60 Hz | 3-phase 380–480 VAC, 50/60 Hz | — | — | |
| Typical power draw(Differs) | 200W | 250W | 280W | 350W | 0.9kW | 1.2kW | 3kW | 0.35kW | 0.35kW | 0.4kW | 3kW | — | — | |
| Tool I/O(Differs) | 2 digital in, 2 digital out, 2 analog in, 24 V 2 A, RS-485 | 2 digital in, 2 digital out, 2 analog in, 24 V 2 A, RS-485 | 2 digital in, 2 digital out, 2 analog in, 24 V 2 A, RS-485 | 2 digital in, 2 digital out, 2 analog in, 24 V 2 A, RS-485 | — | — | — | — | — | — | — | — | 2 digital in, 2 digital out, 2 analog in, 24 V 2 A, RS-485 | |
| Robot cable(Differs) | 6m | 6m | 6m | 6m | — | — | — | — | — | — | — | — | — | |
| Fieldbus and network(Differs) | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | Modbus TCP · EtherNet/IP · PROFINET · OPC UA | |
| Teach pendant(Differs) | HGT-12 (12-inch touch screen) | HGT-12 (12-inch touch screen) | HGT-12 (12-inch touch screen) | HGT-12 (12-inch touch screen) | HGT-12 (12-inch touch screen) | HGT-12 (12-inch touch screen) | HGT-12 (12-inch touch screen) | HGT-12 (12-inch touch screen) | HGT-12 (12-inch touch screen) | HGT-12 (12-inch touch screen) | HGT-12 (12-inch touch screen) | — | HGT-12 (12-inch touch screen) | |
| Software(Differs) | Hangyeol Studio 3.2 | Hangyeol Studio 3.2 | Hangyeol Studio 3.2 | Hangyeol Studio 3.2 | Hangyeol Studio 3.2 | Hangyeol Studio 3.2 | Hangyeol Studio 3.2 | Hangyeol Studio 3.2 | Hangyeol Studio 3.2 | Hangyeol Studio 3.2 | Hangyeol Studio 3.2 with pattern editor | — | — | |
| Supply capacity(Differs) | — | — | — | — | 2kVA | 2.5kVA | 9kVA | 1.5kVA | 1.5kVA | 2kVA | 9kVA | — | — | |
| Built-in utilities(Differs) | — | — | — | — | Air Ø6 × 2, 8 signal wires, 1 Ethernet | Air Ø6 × 2, 8 signal wires, 1 Ethernet | Air Ø10 × 1, 24 signal wires, 1 Ethernet | 15 signal wires, air Ø6 × 2 and Ø4 × 1User wiring and air | 15 signal wires, air Ø6 × 2 and Ø4 × 1User wiring and air | 15 signal wires, air Ø6 × 2 and Ø4 × 1User wiring and air | Air Ø12 × 2, 24 signal wires | — | — | |
| Wireless(Differs) | — | — | — | — | — | — | — | — | — | — | — | Wi-Fi, 2.4 / 5 GHz | Wi-Fi, 2.4 / 5 GHz | |
| Deck I/O(Differs) | — | — | — | — | — | — | — | — | — | — | — | 8 digital in, 8 digital out, 24 V, Ethernet | — | |
| Fleet management(Differs) | — | — | — | — | — | — | — | — | — | — | — | Routes and jobs assigned in Hangyeol Studio | Routes and jobs assigned in Hangyeol Studio | |
| Environment | ||||||||||||||
| IP rating(Differs) | IP66 | IP66 | IP66 | IP54 | IP54 body, IP67 wrist | IP54 body, IP67 wrist | IP54 body, IP67 wrist | IP20 (IP65 sealed version available) | IP20 (IP65 sealed version available) | IP20 (IP65 sealed version available) | IP54 body, IP67 wrist | IP52 | IP52 base, IP66 arm | |
| Operating temperature(Differs) | 0–45°C | 0–45°C | 0–45°C | 0–45°C | 0–45°C | 0–45°C | 0–45°C | 5–40°C | 5–40°C | 5–40°C | 0–45°C | 5–40°C | 5–40°C | |
| Humidity(Differs) | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | 90% or less, non-condensing | |
| Noise(Differs) | Under 65 dB(A) | Under 65 dB(A) | Under 65 dB(A) | Under 65 dB(A) | Under 70 dB(A) | Under 70 dB(A) | Under 71 dB(A) | Under 70 dB(A) | Under 70 dB(A) | Under 70 dB(A) | Under 71 dB(A) | — | — | |
| Status display(Differs) | Wrist light ring: idle, running, collaborative slowdown, stop | Wrist light ring: idle, running, collaborative slowdown, stop | Wrist light ring: idle, running, collaborative slowdown, stop | Wrist light ring: idle, running, collaborative slowdown, stop | — | — | — | — | — | — | — | — | — | |
| Cleanroom(Differs) | — | — | — | — | — | — | — | ISO 14644-1 Class 4 (option) | ISO 14644-1 Class 4 (option) | ISO 14644-1 Class 4 (option) | — | — | — | |
| Floor(Differs) | — | — | — | — | — | — | — | — | — | — | — | Indoor, level floors (up to 2% slope) | Indoor, level floors (up to 2% slope) | |
| Safety and compliance | ||||||||||||||
| Safety(Differs) | Complies with ISO 10218-1 | Complies with ISO 10218-1 | Complies with ISO 10218-1 | Complies with ISO 10218-1 | Complies with ISO 10218-1 | Complies with ISO 10218-1 | Complies with ISO 10218-1 | Complies with ISO 10218-1 | Complies with ISO 10218-1 | Complies with ISO 10218-1 | Complies with ISO 10218-1 | — | Complies with ISO 10218-1 | |
| Functional safety(Differs) | 18 safety functions, ISO 13849-1 PL d / Cat. 3 | 18 safety functions, ISO 13849-1 PL d / Cat. 3 | 18 safety functions, ISO 13849-1 PL d / Cat. 3 | 18 safety functions, ISO 13849-1 PL d / Cat. 3 | E-stop and protective stop circuits, ISO 13849-1 PL d / Cat. 3 | E-stop and protective stop circuits, ISO 13849-1 PL d / Cat. 3 | E-stop and protective stop circuits, ISO 13849-1 PL d / Cat. 3 | E-stop and protective stop circuits, ISO 13849-1 PL d / Cat. 3 | E-stop and protective stop circuits, ISO 13849-1 PL d / Cat. 3 | E-stop and protective stop circuits, ISO 13849-1 PL d / Cat. 3 | E-stop and protective stop circuits, ISO 13849-1 PL d / Cat. 3 | — | 18 safety functions, ISO 13849-1 PL d / Cat. 3 | |
| Collaborative use(Differs) | Robot for collaborative applications (PFL and SSM)Subject to a risk assessment of the application. | Robot for collaborative applications (PFL and SSM)Subject to a risk assessment of the application. | Robot for collaborative applications (PFL and SSM)Subject to a risk assessment of the application. | Robot for collaborative applications (PFL and SSM)Subject to a risk assessment of the application. | — | — | — | — | — | — | — | — | Robot for collaborative applications (PFL and SSM)Subject to a risk assessment of the application. | |
| Korea(Differs) | KCs self-declaration of safety conformity | KCs self-declaration of safety conformity | KCs self-declaration of safety conformity | KCs self-declaration of safety conformity | KCs self-declaration of safety conformity | KCs self-declaration of safety conformity | KCs self-declaration of safety conformity | KCs self-declaration of safety conformity | KCs self-declaration of safety conformity | KCs self-declaration of safety conformity | KCs self-declaration of safety conformity | — | KCs self-declaration of safety conformityKorea (arm) | |
| EU(Differs) | CE | CE | CE | CE | CE | CE | CE | CE | CE | CE | CE | CE | CE | |
| Safety monitoring(Differs) | — | — | — | — | Safety-rated speed and zone monitoring (option) | Safety-rated speed and zone monitoring (option) | Safety-rated speed and zone monitoring (option) | Safety-rated speed and zone monitoring (option) | Safety-rated speed and zone monitoring (option) | Safety-rated speed and zone monitoring (option) | Safety-rated speed and zone monitoring (option) | — | — | |
| Safety scanners(Differs) | — | — | — | — | — | — | — | — | — | — | — | Two, 360° coverage (front-right and rear-left corners) | Two, 360° coverage (front-right and rear-left corners) | |
| Safety standard(Differs) | — | — | — | — | — | — | — | — | — | — | — | Designed to ISO 3691-4 | Designed to ISO 3691-4 | |
| Functional safety (base)(Differs) | — | — | — | — | — | — | — | — | — | — | — | 13 safety functions, ISO 13849-1 PL d | 13 safety functions, ISO 13849-1 PL d | |
| Arm lock(Differs) | — | — | — | — | — | — | — | — | — | — | — | — | Arm folded and locked while driving; works only after docking | |
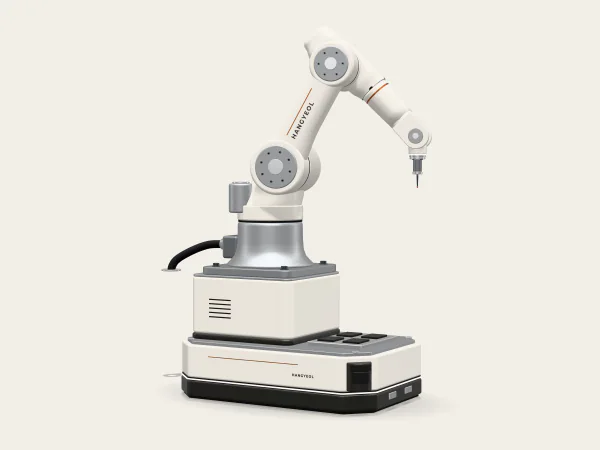
Narrowed it to two? We’ll help with the last step.
Send the shortlist with your process. An engineer will check cycle time and cell layout for each.
- Main line
- +82 53-0614-2700
- Service 24/7
- +82 53-0614-2790
Compare0/4
- 1Empty slot
- 2Empty slot
- 3Empty slot
- 4Empty slot