SCARA
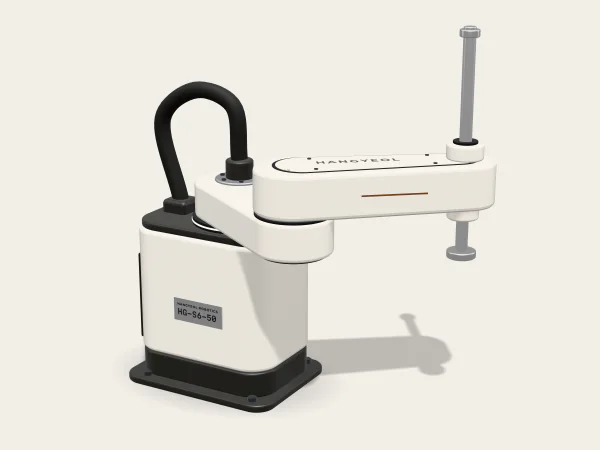
HG-S6-50
A 500 mm SCARA with a 0.32 s standard cycle for fast small-part work on boards
- Payload (rated)
- 3kg
- 6.6 lb · max 6 kg
- Arm length
- 500mm
- 19.7 in
- XY repeatability
- ±0.01mm
 Asher Kim Portfolio №02 · This is a fictional company. No real quotes, orders, or consultations. · Fictional company
HG-DWG-000 · Hangyeol Robotics website
Application 4 of 8
Up from the pick point, across at a fixed height, and down onto the place point. The move can last 0.3 s or span the whole plant.
Process sequence
Scroll down and each step lights up in copper on the plate.
An overhead camera finds each part’s position and orientation.
A vacuum pad or gripper takes the part.
An upward-looking camera checks the grip and corrects the place point.
The robot descends to the set height and places or inserts the part.
Design points
The lower the transfer height, the less time spent going up and down. We set the heights of nearby equipment together.
One look before the pick and another before the place absorb part-to-part variation.
When stations are far apart, use an HG-M600 instead of laying conveyor. When the flow changes, just edit the map.
Recommended robots
Short moves, like pressing connectors into boards or moving parts out of trays, belong to SCARA robots. The HG-S6-50 runs the standard cycle in 0.32 s. A camera reads each part’s position and corrects the placement.
Long moves between processes belong to the HG-M600. It carries 600 kg along a mapped route and stops within ±3 mm at each station.
When the task sits on a workbench close to people, choose the HG-C5-09 cobot.
SCARA
A 500 mm SCARA with a 0.32 s standard cycle for fast small-part work on boards
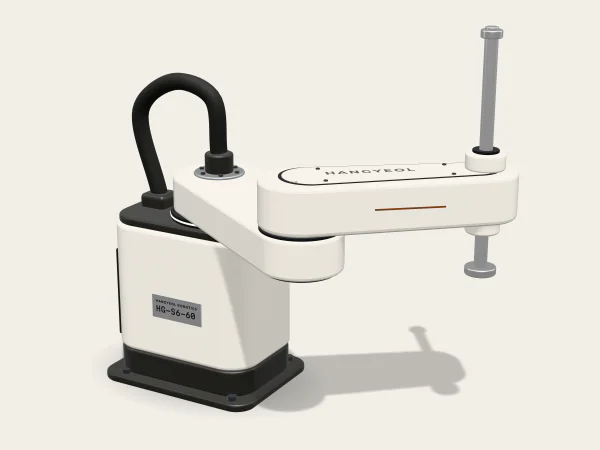
SCARA
A 600 mm SCARA with a 0.34 s standard cycle and a wider work area
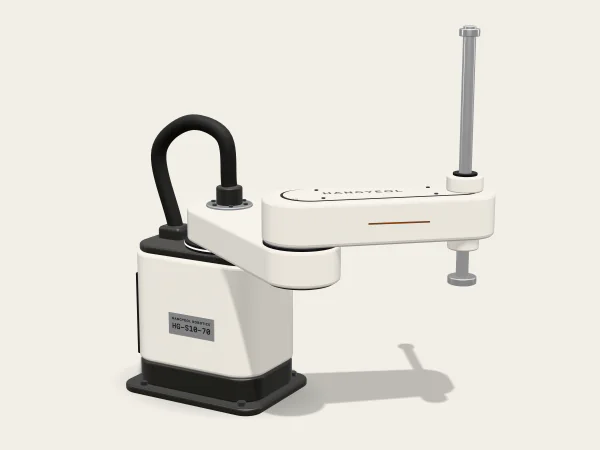
SCARA
A 700 mm SCARA for up to 10 kg, built for heavier assembly and screwdriving
Cases
Cheonan, Chungnam · Electronic components maker
HG-S6-50 × 8
0.41 → 0.33sCycle time per partExample
Namdong, Incheon · Distribution center
HG-M600 × 5
31kmWalking replaced per dayExample
Industries that use this process most
Share part drawings or a video of the current process. An application engineer will work through the cell layout and cycle time with you.