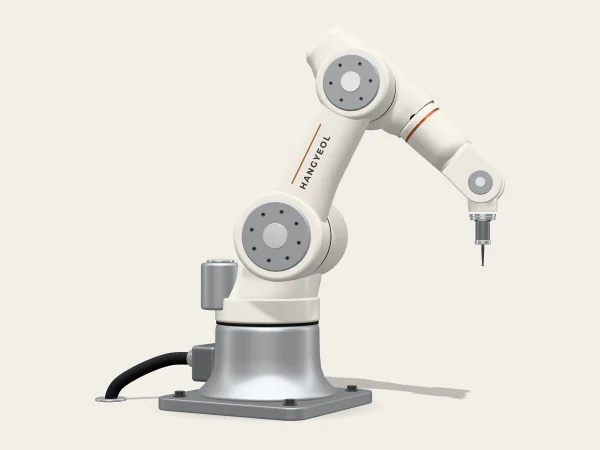
Welding
Arc and spot welding, from seat frames to body parts
 Asher Kim Portfolio №02 · This is a fictional company. No real quotes, orders, or consultations. · Fictional company
HG-DWG-000 · Hangyeol Robotics website
Collaborative robots HG-C
6-axis robots for collaborative applications, 5 to 25 kg
Six-axis arms with a torque sensor in every joint. Each joint measures contact force and stops the arm once it passes the limit you set. Teach positions by guiding the arm by hand, then build the task in blocks on the 12-inch pendant.
Whether a task can run collaboratively is decided by a risk assessment of the whole application, including the tool, the workpiece, and nearby equipment (ISO 10218-2:2025, ISO 12100). In Korea, Article 223 of the Rules on Occupational Safety and Health Standards requires a fence or an equivalent collision-prevention measure, and the installed robot must pass a safety inspection.
Models
Numbers line up in fixed-width columns. Add any model to compare it with robots from other families.
| Model | Payload | Reach | Repeatability | Weight | IP rating | Max TCP speed | Compare |
|---|---|---|---|---|---|---|---|
| HG-C5-09 | 5kg11 lb | 900mm35.4 in | ±0.03mm | 22kg49 lb | IP66 | 1m/s | |
| HG-C10-13 | 10kg22 lb | 1,300mm51.2 in | ±0.03mm | 33kg73 lb | IP66 | 2m/s | |
| HG-C16-10 | 16kg35 lb | 1,000mm39.4 in | ±0.05mm | 34kg75 lb | IP66 | 1.5m/s | |
| HG-C25-17 | 25kg55 lb | 1,700mm66.9 in | ±0.1mm | 72kg159 lb | IP54 | 2m/s |
Same scale
Every model is drawn at the same scale on one floor line. The bars below give reach at the same scale.
What all four share
From the second generation on, all six joints measure load directly. You can set collision detection and force limits at lower forces.
Eighteen safety functions, including force, speed, position, and zone limits, run to ISO 13849-1 PL d / Cat. 3. Whether a task runs collaboratively is set by an application risk assessment.
A light ring at the wrist shows idle, running, collaborative slowdown, and stop in color. People at the next station can read the robot’s state from across the cell.
The C5, C10, and C16 are rated IP66 for machining cells with coolant and dust. The largest model, the HG-C25-17, is IP54.
Applications
Each application page shows the motion path, the process steps, and the models we recommend.
Arc and spot welding, from seat frames to body parts
Stacking cases and bags in the same pattern at the end of the line
Loading blanks into CNC machines and presses, and unloading finished parts
Picking parts, placing them on the mark, and moving them between processes
Driving bolts and screws to torque and fitting parts together
Removing burrs from castings and machined parts, and sanding surfaces smooth
Carrying cameras and sensors to every check point in the same order
Laying sealant and adhesive in one even, unbroken bead
Tell us what the robot has to lift, how far it has to reach, and how fast the line runs. An engineer will reply with a model and a cell layout.