Pick and place
Picking parts, placing them on the mark, and moving them between processes
 Asher Kim Portfolio №02 · This is a fictional company. No real quotes, orders, or consultations. · Fictional company
HG-DWG-000 · Hangyeol Robotics website
Collaborative robots HG-C
Our smallest cobot: 5 kg and 900 mm, sized for benchtop assembly, inspection, and dispensing
This is a demo, so there is no real file.
On a real site, the file would download right away. Datasheets, drawings, and CAD models need no login or form.

At 22 kg with a 150 mm base, it fits on the corner of a workbench. It repeats to ±0.03 mm for small-part insertion and carries a camera from one inspection point to the next. Max TCP speed is held to 1 m/s.
Body and installation
A 150 mm base
Four bolts fix it to a small spot on the bench.
±0.03 mm
Precise enough to insert small connectors and pins.
Six torque sensors
Each joint measures contact force and stops at the limit you set.
Whether a task can run collaboratively is decided by a risk assessment of the whole application, including the tool, the workpiece, and nearby equipment (ISO 10218-2:2025, ISO 12100). In Korea, Article 223 of the Rules on Occupational Safety and Health Standards requires a fence or an equivalent collision-prevention measure, and the installed robot must pass a safety inspection.
Drawings
Outline drawings from the front, side, and top, plus the work envelope. They come from the same dimension data as the 3D view, so the two always agree. CAD files are under Downloads.


Specifications
Repeatability follows ISO 9283, and every SCARA cycle time uses the same standard motion, so any two models compare directly.
Reach35.4 in
900mm
The farthest the tool flange center reaches from the base center.
| Payload | 5 kg (11 lb) |
|---|---|
| Reach | 900 mm (35.4 in) |
| Repeatability | ±0.03 mmPer ISO 9283 |
| Axes | 6 |
| Weight | 22 kg (49 lb)Without cable |
| Mounting | Any orientation: floor, wall, ceiling, or tilted |
| Base diameter | 150 mm (5.9 in) |
| Tool flange | ISO 9409-1-50-4-M6 |
| Max TCP speed | 1 m/s |
|---|---|
| Force sensing | Torque sensors in all six joints (2nd gen) |
| TCP force accuracy | ±3 N |
| Hand guiding | Press the wrist button, guide the arm, save the point |
| Controller | HGC-7 compact cabinet |
|---|---|
| Power supply | Single-phase 100–240 VAC, 50/60 Hz |
| Typical power draw | 200 W |
| Tool I/O | 2 digital in, 2 digital out, 2 analog in, 24 V 2 A, RS-485 |
| Robot cable | 6 m |
| Fieldbus and network | Modbus TCP · EtherNet/IP · PROFINET · OPC UA |
| Teach pendant | HGT-12 (12-inch touch screen) |
| Software | Hangyeol Studio 3.2 |
| IP rating | IP66 |
|---|---|
| Operating temperature | 0–45 °C |
| Humidity | 90% or less, non-condensing |
| Noise | Under 65 dB(A) |
| Status display | Wrist light ring: idle, running, collaborative slowdown, stop |
| Safety | Complies with ISO 10218-1 |
|---|---|
| Functional safety | 18 safety functions, ISO 13849-1 PL d / Cat. 3 |
| Collaborative use | Robot for collaborative applications (PFL and SSM)Subject to a risk assessment of the application. |
| Korea | KCs self-declaration of safety conformity |
| EU | CE |
Applications
Each application page shows the motion path, the process steps, and how the cell is laid out.
Picking parts, placing them on the mark, and moving them between processes
Driving bolts and screws to torque and fitting parts together
Carrying cameras and sensors to every check point in the same order
Laying sealant and adhesive in one even, unbroken bead
Downloads
Datasheets, drawings, and 3D models download without a login. This is a demo, so the files themselves are not real.
This is a demo, so there is no real file.
On a real site, the file would download right away. Datasheets, drawings, and CAD models need no login or form.
More collaborative robots
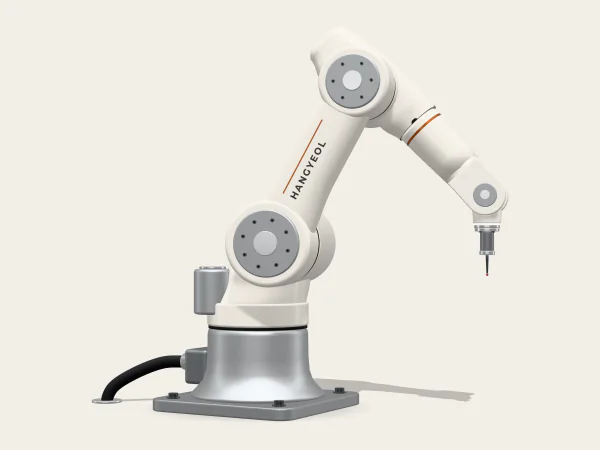
Collaborative robots
Our flagship cobot: 10 kg and 1,300 mm, from machine tending to welding
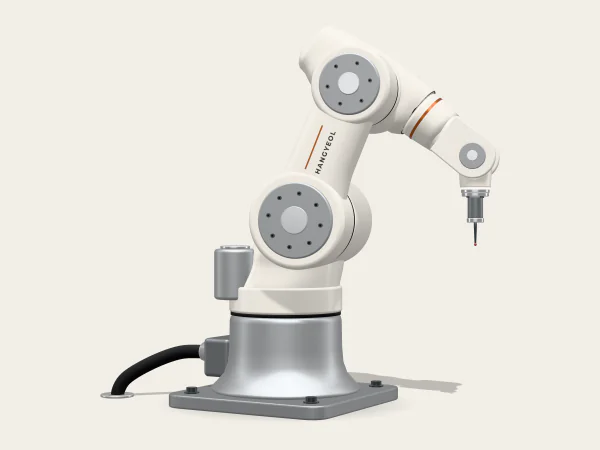
Collaborative robots
16 kg and 1,000 mm: a cobot for heavy tools in screwdriving and tending
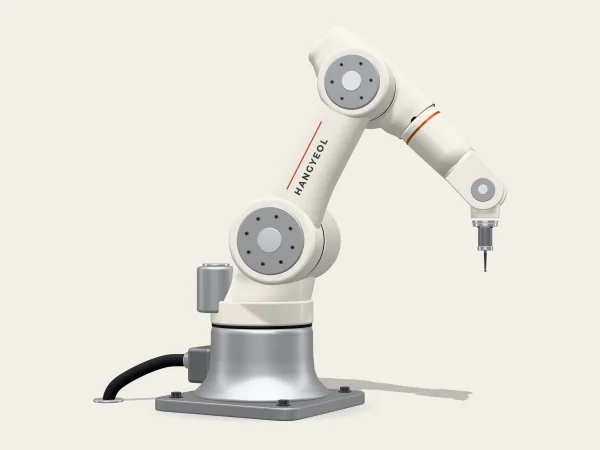
Collaborative robots
Our largest cobot: 25 kg and 1,700 mm for end-of-line palletizing and large-part tending
Tell us the tool, the part, and the cycle time you need. We will reply with a cell layout and a quote. The model is already filled in on the form.