Machine tending
Loading blanks into CNC machines and presses, and unloading finished parts
 Asher Kim Portfolio №02 · This is a fictional company. No real quotes, orders, or consultations. · Fictional company
HG-DWG-000 · Hangyeol Robotics website
Mobile robots HG-M
An HG-M600 with an HG-C10-13 cobot on top that moves between stations and works with its arm
This is a demo, so there is no real file.
On a real site, the file would download right away. Datasheets, drawings, and CAD models need no login or form.

An HG-M600 carrying an HG-C10-13 cobot. It docks at a machine, reads a reference marker with its wrist camera to correct its position, then goes to work with the arm. One robot can make the rounds of several CNC machines or test stations, loading and unloading parts.
Body and installation
±0.2 mm after docking
Marker correction brings the work position within ±0.2 mm.
Arm moves only when parked
The arm folds and locks while driving and moves only after docking.
100 kg parts shelf
Carries trays of raw and finished parts.
One controller
Program the route and the arm task together in Hangyeol Studio.
Whether a task can run collaboratively is decided by a risk assessment of the whole application, including the tool, the workpiece, and nearby equipment (ISO 10218-2:2025, ISO 12100). In Korea, Article 223 of the Rules on Occupational Safety and Health Standards requires a fence or an equivalent collision-prevention measure, and the installed robot must pass a safety inspection.
Drawings
Outline drawings from the front, side, and top, plus the work envelope. They come from the same dimension data as the 3D view, so the two always agree. CAD files are under Downloads.


Specifications
Repeatability follows ISO 9283, and every SCARA cycle time uses the same standard motion, so any two models compare directly.
Arm reach51.2 in
1,300mm
The reach of the HG-C10-13 arm on top.
| Arm | HG-C10-13 |
|---|---|
| Arm payload | 10 kg (22 lb) |
| Arm reach | 1,300 mm (51.2 in) |
| Arm repeatability | ±0.03 mmPer ISO 9283 |
| Work position accuracy | ±0.2 mmAfter correction with the wrist camera on a station marker |
| Parts shelf load | 100 kg (220 lb) |
| Length | 1,120 mm (44.1 in) |
| Width | 760 mm (29.9 in) |
| Arm base height | 630 mm (24.8 in)From the floor |
| Weight | 231 kg (509 lb)Arm included |
| Top speed | 1.5 m/sWith the arm folded and locked |
|---|---|
| Turning | Turns in place (zero radius) |
| Turning space | 1,400 mm (55.1 in)Diameter |
| Minimum aisle width | 1,000 mm (39.4 in)One-way traffic |
| Docking accuracy | ±3 mm |
| Positioning accuracy in transit | ±100 mm |
| Navigation | Laser-map navigation; reflective markers for docking |
| Max step and gap | 10 / 20 mm |
| Arm max TCP speed | 2 m/s |
| Battery | Lithium iron phosphate, 48 V, 70 Ah |
|---|---|
| Run time | 6 hIncluding arm work |
| Charge time | 3 h0 to 100% |
| Charging | Automatic dock or manual charger |
| Battery life | 3,000+ cycles |
| Controller | HGC-7, built in: one controller for base and arm |
|---|---|
| Wireless | Wi-Fi, 2.4 / 5 GHz |
| Tool I/O | 2 digital in, 2 digital out, 2 analog in, 24 V 2 A, RS-485 |
| Fieldbus and network | Modbus TCP · EtherNet/IP · PROFINET · OPC UA |
| Teach pendant | HGT-12 (12-inch touch screen) |
| Fleet management | Routes and jobs assigned in Hangyeol Studio |
| IP rating | IP52 base, IP66 arm |
|---|---|
| Operating temperature | 5–40 °C |
| Humidity | 90% or less, non-condensing |
| Floor | Indoor, level floors (up to 2% slope) |
| Safety scanners | Two, 360° coverage (front-right and rear-left corners) |
|---|---|
| Arm lock | Arm folded and locked while driving; works only after docking |
| Safety standard | Designed to ISO 3691-4 |
| Functional safety (base) | 13 safety functions, ISO 13849-1 PL d |
| Safety | Complies with ISO 10218-1 |
| Functional safety | 18 safety functions, ISO 13849-1 PL d / Cat. 3 |
| Collaborative use | Robot for collaborative applications (PFL and SSM)Subject to a risk assessment of the application. |
| Korea (arm) | KCs self-declaration of safety conformity |
| EU | CE |
Applications
Each application page shows the motion path, the process steps, and how the cell is laid out.
Loading blanks into CNC machines and presses, and unloading finished parts
Picking parts, placing them on the mark, and moving them between processes
Carrying cameras and sensors to every check point in the same order
Downloads
Datasheets, drawings, and 3D models download without a login. This is a demo, so the files themselves are not real.
This is a demo, so there is no real file.
On a real site, the file would download right away. Datasheets, drawings, and CAD models need no login or form.
Same family and others
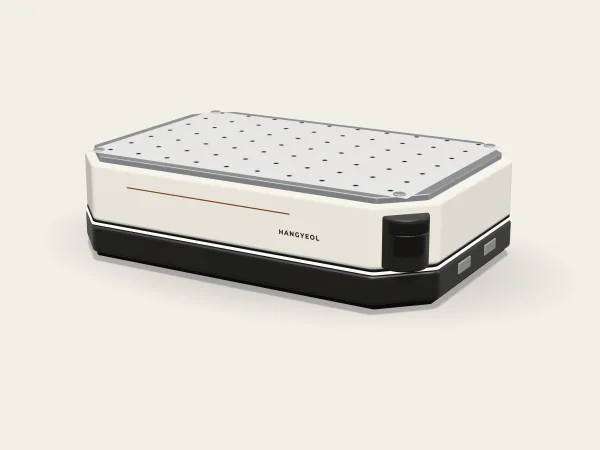
Mobile robots
An autonomous mobile robot that carries 600 kg between processes and docks within ±3 mm
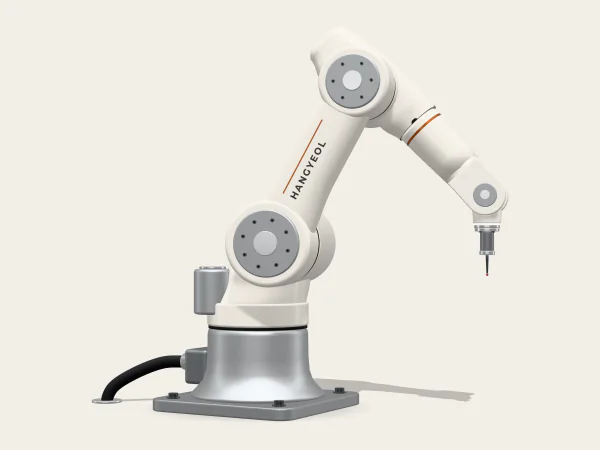
Collaborative robots
Our flagship cobot: 10 kg and 1,300 mm, from machine tending to welding
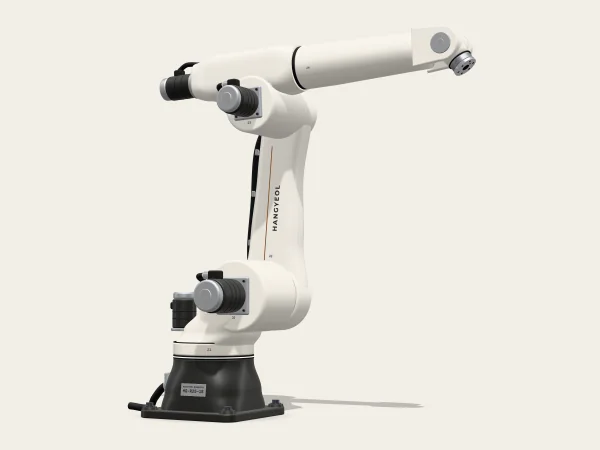
Industrial 6-axis
A 25 kg, 1,800 mm arm for heavier torches, grippers, and wider work areas
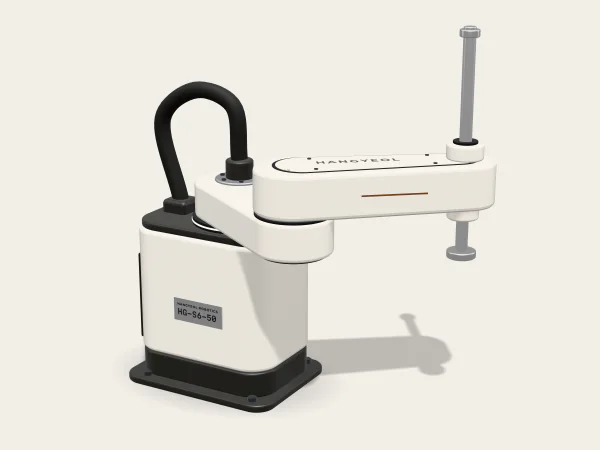
SCARA
A 500 mm SCARA with a 0.32 s standard cycle for fast small-part work on boards
Tell us the tool, the part, and the cycle time you need. We will reply with a cell layout and a quote. The model is already filled in on the form.