Palletizing
Stacking cases and bags in the same pattern at the end of the line
 Asher Kim Portfolio №02 · This is a fictional company. No real quotes, orders, or consultations. · Fictional company
HG-DWG-000 · Hangyeol Robotics website
Palletizing HG-P
A 4-axis palletizer, 180 kg and 3,100 mm, running 1,800 cycles an hour at the end of the line
This is a demo, so there is no real file.
On a real site, the file would download right away. Datasheets, drawings, and CAD models need no login or form.

A four-axis robot that stacks cases, bags, and bundles onto pallets. It runs the 400–2,000–400 mm pattern 1,800 times an hour, even at its full 180 kg. Parallel links keep the wrist level, which keeps the gripper simple.
Body and installation
1,800 cycles an hour
At the full 180 kg load on the 400–2,000–400 mm pattern.
Two pallet stations
It fills the pallets on both sides in turn and keeps working while one is swapped.
Slip sheets and empty pallets
The same robot lays slip sheets between layers and sets out empty pallets.
Drawings
Outline drawings from the front, side, and top, plus the work envelope. They come from the same dimension data as the 3D view, so the two always agree. CAD files are under Downloads.


Specifications
Repeatability follows ISO 9283, and every SCARA cycle time uses the same standard motion, so any two models compare directly.
Reach122 in
3,100mm
The farthest the wrist axis reaches from the J1 axis.
| Payload | 180 kg (397 lb) |
|---|---|
| Reach | 3,100 mm (122 in) |
| Repeatability | ±0.05 mmPer ISO 9283 |
| Axes | 4 |
| Weight | 1,300 kg (2,866 lb) |
| Mounting | Floor |
| Base size | 1,000 × 1,000 mm |
| Cycles per hour | 1,800 /hAt 180 kg on the 400–2,000–400 mm pattern |
|---|---|
| Cycles per hour at 120 kg | 2,000 /h400–2,000–400 mm pattern |
| J4 allowable inertia | 100 kg·m² |
| Wrist attitude | Held level by parallel links |
| Controller | HGC-7 standard cabinet |
|---|---|
| Power supply | 3-phase 380–480 VAC, 50/60 Hz |
| Typical power draw | 3 kW |
| Supply capacity | 9 kVA |
| Built-in utilities | Air Ø12 × 2, 24 signal wires |
| Fieldbus and network | Modbus TCP · EtherNet/IP · PROFINET · OPC UA |
| Teach pendant | HGT-12 (12-inch touch screen) |
| Software | Hangyeol Studio 3.2 with pattern editor |
| IP rating | IP54 body, IP67 wrist |
|---|---|
| Operating temperature | 0–45 °C |
| Humidity | 90% or less, non-condensing |
| Noise | Under 71 dB(A) |
| Safety | Complies with ISO 10218-1 |
|---|---|
| Functional safety | E-stop and protective stop circuits, ISO 13849-1 PL d / Cat. 3 |
| Safety monitoring | Safety-rated speed and zone monitoring (option) |
| Korea | KCs self-declaration of safety conformity |
| EU | CE |
Applications
Each application page shows the motion path, the process steps, and how the cell is laid out.
Stacking cases and bags in the same pattern at the end of the line
Anseong, Gyeonggi · Food plant
HG-P180-31 × 2
1,140casesCases per hour, two robotsExample
Downloads
Datasheets, drawings, and 3D models download without a login. This is a demo, so the files themselves are not real.
This is a demo, so there is no real file.
On a real site, the file would download right away. Datasheets, drawings, and CAD models need no login or form.
Other families
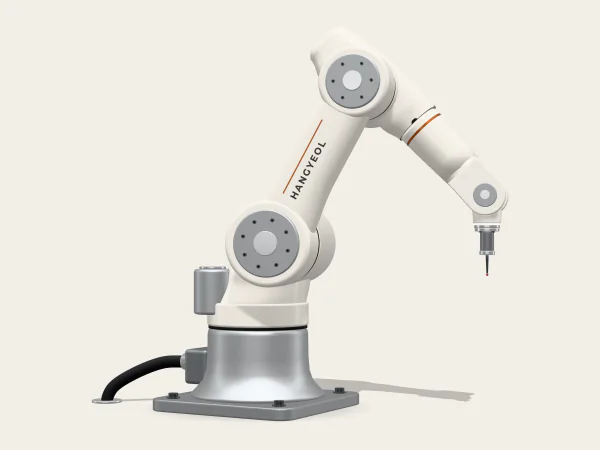
Collaborative robots
Our flagship cobot: 10 kg and 1,300 mm, from machine tending to welding
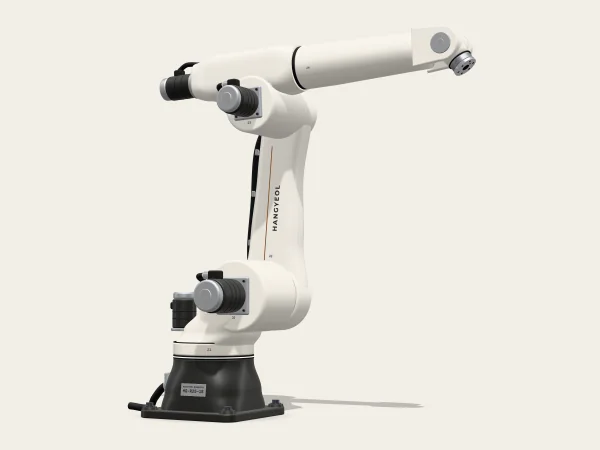
Industrial 6-axis
A 25 kg, 1,800 mm arm for heavier torches, grippers, and wider work areas
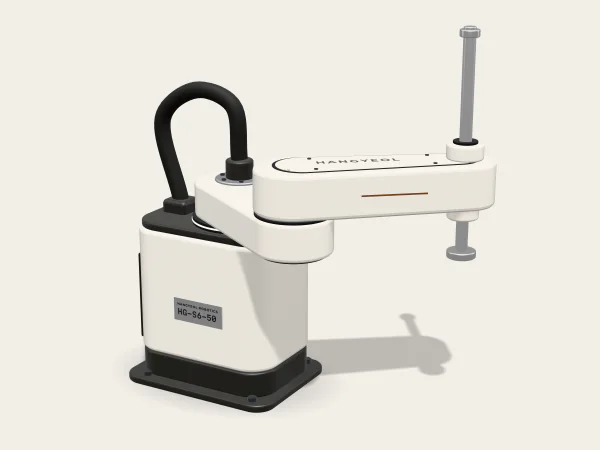
SCARA
A 500 mm SCARA with a 0.32 s standard cycle for fast small-part work on boards
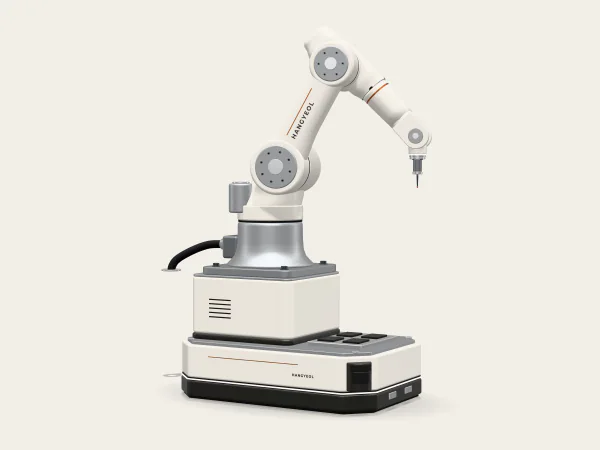
Mobile robots
An HG-M600 with an HG-C10-13 cobot on top that moves between stations and works with its arm
Tell us the tool, the part, and the cycle time you need. We will reply with a cell layout and a quote. The model is already filled in on the form.