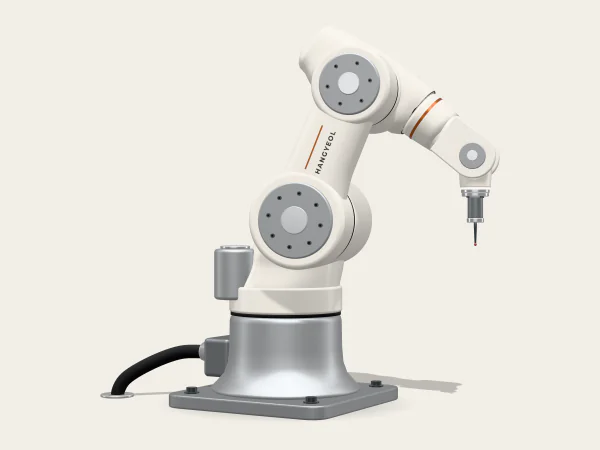
Collaborative robots
HG-C16-10
16 kg and 1,000 mm: a cobot for heavy tools in screwdriving and tending
- Payload
- 16kg
- 35 lb
- Reach
- 1,000mm
- 39.4 in
- Repeatability
- ±0.05mm
 Asher Kim Portfolio №02 · This is a fictional company. No real quotes, orders, or consultations. · Fictional company
HG-DWG-000 · Hangyeol Robotics website
Case 2 · Ochang, Chungbuk · Batteries
Six HG-C16-10 cobots took over module bolting and inspection. Not a single bolt was missed in the first three months, and the line went from two shifts to three.
ExampleAll figures are examples, compared with the same process before automation.
Cell layout
The cell seen from above. Dashed circles show how far each robot’s wrist reaches. Press a + button to open the note for that spot.
10
The module is lifted and clamped. The robots on both sides split its 24 bolts and check each one with a wrist camera.
12
When a person comes within the set distance, the robots slow down, and closer still, they stop. The distances and speeds came from the risk assessment.
Cell layout for a battery module maker in Ochang, Chungbuk, seen from above.
Parts list Select a row to pick out those items on the layout.
Problem → solution → result
Each module takes 24 bolts. Operators drove them with torque tools and another operator checked by eye, but bolts missed on the night shift kept turning up at the customer’s incoming inspection.
Volume called for a third shift, but experienced night-shift operators were hard to find.
Three fastening stations sit along the module conveyor, with two HG-C16-10 cobots at each station splitting the bolts from either side. Torque and angle from the nutrunner are stored for every bolt under the module serial number.
A camera on the same wrist photographs each joint right after fastening, which brought the separate inspection station into the cell. On the side where people do wiring, area scanners placed according to the risk assessment slow the robots when someone approaches.
Zero bolts were missed in the first three months. The line moved from two shifts to three without adding skilled operators, and people now handle wiring and final checks.
Robots and timeline
Collaborative robots
16 kg and 1,000 mm: a cobot for heavy tools in screwdriving and tending
Time on site
2 weeks to install and 3 weeks to commission, over two line shutdowns
More cases
Gyeongsan, Gyeongbuk · Automotive seat-parts maker
HG-R12-14 × 4
19%Shorter cycle timeExample
Anseong, Gyeonggi · Food plant
HG-P180-31 × 2
1,140casesCases per hour, two robotsExample
Changwon, Gyeongnam · Precision machining shop
HG-C10-13 × 3
9hoursUnattended night runExample
These cases are examples made for this portfolio. Customers are not named, and every figure is an example compared with the same process before automation.
Tell us the process and the part. The team behind this case will show you the layout and timeline of a similar cell first.